
Proving the Figure-Eight Orbit Exists: Action Minimisation on the Shape Sphere
Summer research 2024: the three-body problem · Part 9 of 11
A weekly research log from my summer project at the University of Edinburgh, supervised by Prof. Jenni Smillie.
← Sundman's Power Series Solution to the Three-Body Problem (Part II) · Classifying and Finding New Possible Orbits (Part I) →
This post outlines the proof that the figure-eight orbit exists, following Chenciner and Montgomery. It uses the shape sphere together with the direct method of the calculus of variations.
Outline of the proof
- On the shape sphere, minimise the action over paths that start at an Euler configuration (three bodies collinear, one at the midpoint of the other two) and end at an isosceles configuration. The minimiser is one twelfth of the orbit.
- Show that the minimiser has no collisions. Let \(A_2\) be a lower bound for the action of any path with a collision, and exhibit a collision-free test path whose action is smaller than \(A_2\). Then the minimiser cannot collide.
- Use the symmetries of the equal-mass problem to make twelve copies of this arc, and show that they join smoothly into one closed curve on the shape sphere.
- Reconstruct the motion in the plane from the curve on the shape sphere, and show that the three bodies follow a single figure-eight-shaped curve.
The figure eight is special: numerical work by Simó indicates that it is stable, which is very rare among choreographies (orbits in which all the bodies follow the same curve). By contrast, Lagrange’s equilateral circular orbit with three equal masses is a choreography too, but it is unstable (see Routh’s criterion in part 8).
Step 1: finding minimisers
The action
Following Chenciner and Montgomery, define the action
\[A = \int_{0}^{T} \left(\tfrac{1}{2}K+U\right) dt ,\]where \(K = \lvert\dot x\rvert^2\) is twice the kinetic energy and \(U\) is the force function (the negative of the potential energy). The action is minimised over the set \(\Lambda\) of paths in the Sobolev space \(H^1([0,T], X)\) that start at an Euler configuration (of arbitrary size) and end at an isosceles configuration. Here
\[X = \left\{ x=(x_1, x_2, x_3) \in \mathbb{C}^3 \;\middle|\; \sum_{i=1}^{3} x_i =0 \right\},\]and \(H^1\) consists of paths that, together with their time derivatives, are square integrable, which is the right setting for the direct method.
Step 2: the minimiser has no collisions
Collisions are expensive
If a path in \(\Lambda\) has a collision (double or triple), its action is at least \(A_2\), where \(A_2\) is the action of the collinear two-body solution in which two unit masses start at collision and come to rest a time \(T\) later, with the centre of mass fixed.
A cheaper test path
The Euler equipotential length satisfies \(\ell_0< \pi/5\). Using this bound, one constructs an explicit collision-free test path, running along an equipotential curve on the shape sphere, whose action \(a\) is smaller than \(A_2\).
Conclusion
Putting these together,
\[\min_{\Lambda} A \;\le\; a \;<\; A_2 \;\le\; A(\text{any colliding path}),\]so the minimiser is collision-free.
Step 3: assembling the full orbit
The main difficulty is to show that the copies fit together smoothly at their endpoints.
The first task is to show that the minimising arc meets the two curves \(E_3\) and \(M_1\) that constrain its endpoints at right angles. Recall the first variation of the action:
\[\delta A = \epsilon \left[ \frac{\partial L}{\partial \dot{x}}\, \eta \right]_0^T + \epsilon \int_0^T \left(\frac{\partial L}{\partial x} - \frac{d}{dt} \frac{\partial L}{\partial \dot{x}}\right) \eta \, dt .\]Usually the boundary term vanishes because the endpoints are fixed, so \(\eta(0)=\eta(T)=0\). Here the endpoints may slide along \(E_3\) and \(M_1\), so \(\eta\) need not vanish there. The integral vanishes because the minimiser satisfies the Euler–Lagrange equations, so we need
\[\left.\frac{\partial L}{\partial \dot{x}}\right|_{t=0} \cdot \eta(0) = 0, \qquad \left.\frac{\partial L}{\partial \dot{x}}\right|_{t=T} \cdot \eta(T) = 0\]for every allowed \(\eta\). Since \(\partial L/\partial \dot{x}\) points along the minimising curve, and \(\eta\) can be any vector tangent to the constraint curves, the minimising arc must meet \(E_3\) and \(M_1\) orthogonally. Reflecting across these curves then extends the arc smoothly.
Step 4: from the shape sphere back to the plane
Periodicity
Suppose the curve on the shape sphere is closed. Then the initial and final triangles in the plane are similar, because they correspond to the same point of the shape sphere. What is the angle of rotation between them?
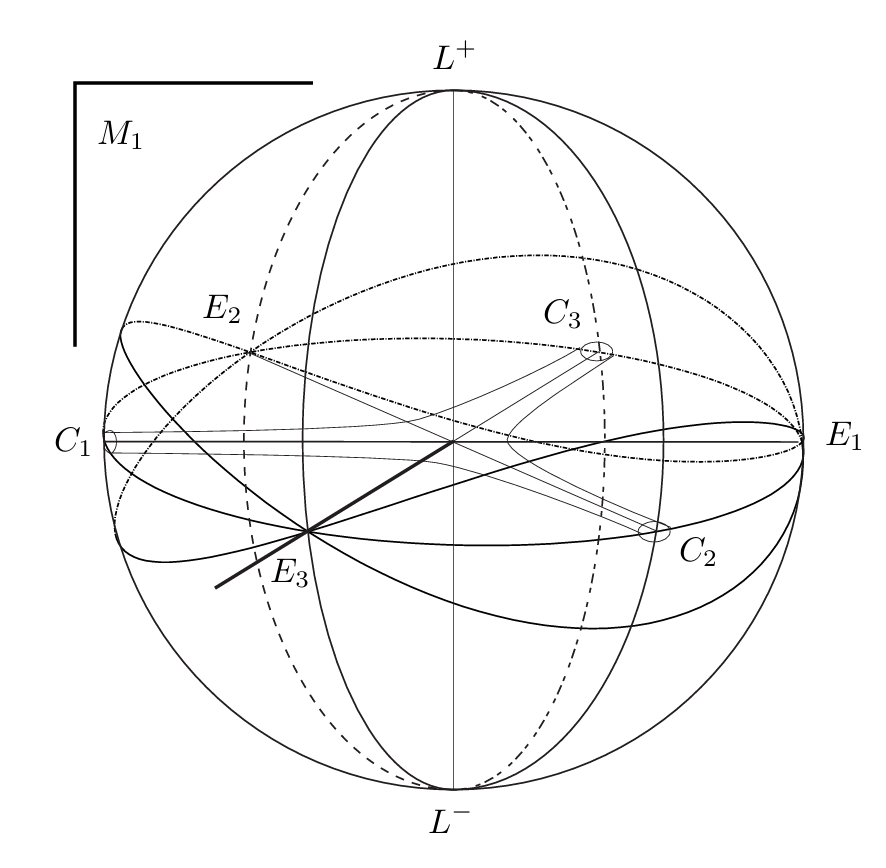
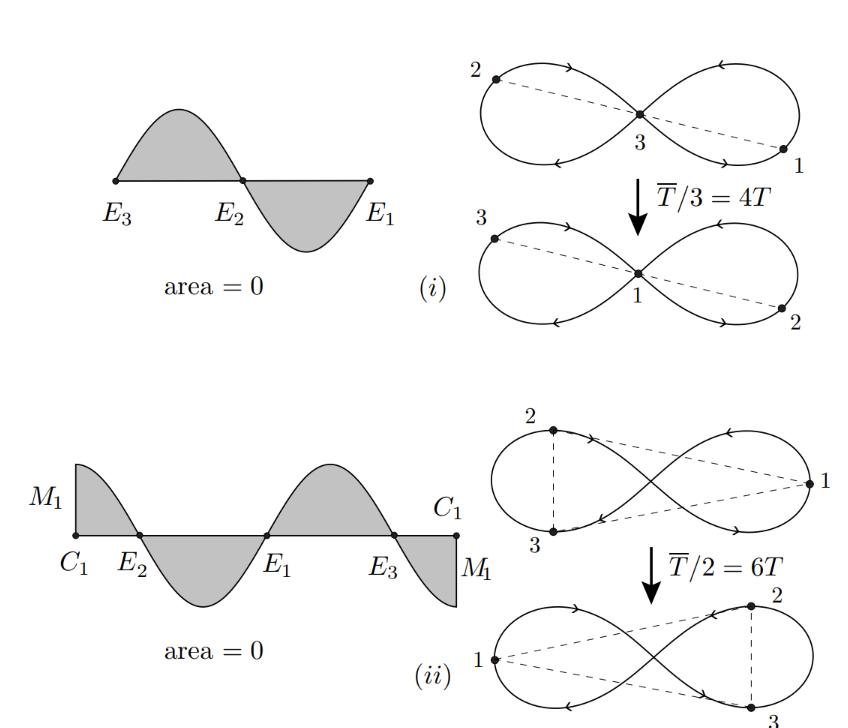
For motions with zero angular momentum, the area rule answers this: the rotation angle equals twice the spherical area enclosed by the shape curve (on the shape sphere of radius \(\tfrac12\), as normalised by Chenciner and Montgomery).
The figure below defines the points \(E_i\) on the equator (the collinear configurations with body \(i\) in the middle) and the meridian \(M_1\):
Combining the area rule with the symmetries shows that the three bodies move along the same curve and differ only by a phase:
No extra loops
Finally, one shows that the angular momentum of each individual body about the centre of mass vanishes only when that body passes through the origin. So each body’s polar angle changes monotonically on each lobe, and each lobe is star-shaped: the curve has no extra loops. The curve traced out is therefore a figure eight.
Progress
This has been a long and intense stretch of the project, but I am well ahead of my original plan.
Credits
This proof is not original. It follows A. Chenciner and R. Montgomery, A remarkable periodic solution of the three-body problem in the case of equal masses, Annals of Mathematics 152 (2000), 881–901, and the presentation I’ve Got a Three-Body Problem by Gareth E. Roberts (College of the Holy Cross).
Changes on 25 October 2026
What was wrong. The outline stated the key step the wrong way round. It said to show that every collision-free path has a smaller action than the cheapest path with a collision. What the proof needs is one collision-free test path whose action is below a lower bound for all paths with collisions; then the minimiser cannot collide.
What changed. The outline is rewritten in numbered steps, the configuration space is written \(X\) instead of \(\chi\), and the variational argument at the end is tidied. Previously titled “A Proof of the Existence of the Figure-8 Orbit using Actions and the Shape Sphere”.