
This article has two parts for two audiences. The first part assumes some advanced classical mechanics (Lagrangian dynamics and the variational principle). The second part needs only basic calculus.
Translational symmetry and conserved momentum
A full proof of Noether’s theorem is quite involved, but the one-dimensional case already shows the idea.
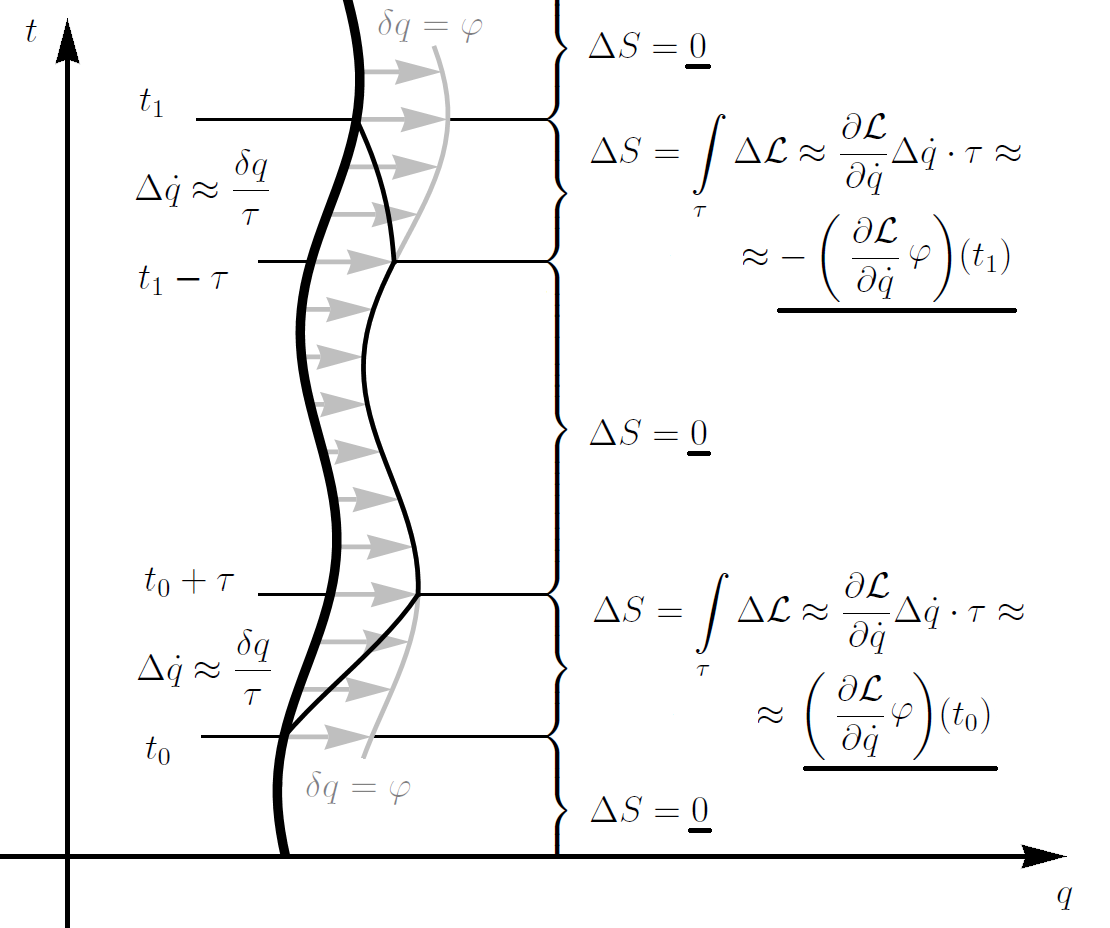
Suppose the system has translational symmetry, \(q \mapsto q + \delta q\): shifting a trajectory by \(\delta q\) does not change the Lagrangian. Take a true trajectory (the bold line in the figure below) and build a varied path that follows it, switches onto the shifted trajectory (the lighter line) over a short time \(\tau\) around \(t_0\), and switches back over a short time \(\tau\) around \(t_1\).
The action is \(S = \int L \, dt\), so \(\Delta S=\int \Delta L \, dt\). Away from the two switches, \(L\) is unchanged by the symmetry. During a switch, \(L\) does not depend on \(q\) itself, so to first order
\[\Delta L \approx \frac{\partial L}{\partial \dot{q}}\, \Delta \dot{q}, \qquad \Delta \dot{q}=\pm \frac{\delta q}{\tau},\]with the \(+\) sign when switching on and the \(-\) sign when switching off. Each switch therefore contributes
\[\int_{\text{switch}} \frac{\partial L}{\partial \dot{q}}\left( \pm \frac{\delta q}{\tau}\right) dt \approx \pm \frac{\partial L}{\partial \dot{q}}\, \delta q .\]Since the true path makes the action stationary, \(\Delta S = 0\) to first order, so the two contributions cancel:
\[\left(\frac{\partial L}{\partial \dot{q}}\, \delta q\right)\Big|_{t_0}=\left(\frac{\partial L}{\partial \dot{q}}\, \delta q\right)\Big|_{t_1},\]so the momentum \(p = \partial L/\partial \dot q\) is the same at all times: it is conserved. The same conclusion follows directly from the Euler–Lagrange equations, as shown in Why is momentum conserved?.
Exercises
- Draw the varied path and check the sign of \(\Delta \dot q\) at each switch. (Undergraduate, year 1)
- Why is the change in action \(\Delta S\) zero? (Undergraduate, years 2–3)
- Why is the \(\dot{q}\) term the only one that contributes? (Hint: \(\tau\) is taken to approach \(0\).) (Undergraduate, years 2–3)
Rotational symmetry and conserved angular momentum
In plane polar coordinates the unit vectors are
\[\hat{\mathbf{r}}=\cos \theta\, \hat{\mathbf{x}}+\sin \theta\, \hat{\mathbf{y}}, \quad \hat{\boldsymbol{\theta}}=-\sin \theta\, \hat{\mathbf{x}}+\cos \theta\, \hat{\mathbf{y}} .\]By the chain rule,
\[\begin{aligned} \dot{\hat{\mathbf{r}}}&=\dot{\theta}\left(-\sin \theta\, \hat{\mathbf{x}}+\cos \theta\, \hat{\mathbf{y}}\right)=\dot{\theta}\, \hat{\boldsymbol{\theta}}, \\ \dot{\hat{\boldsymbol{\theta}}}&=\dot{\theta}\left(-\cos \theta\, \hat{\mathbf{x}}-\sin \theta\, \hat{\mathbf{y}}\right)=-\dot{\theta}\, \hat{\mathbf{r}} , \end{aligned}\]so the velocity is
\[\dot{\mathbf{r}}=\frac{d}{d t}(r \hat{\mathbf{r}})=\dot{r} \hat{\mathbf{r}}+r \dot{\hat{\mathbf{r}}}=\dot{r} \hat{\mathbf{r}}+r \dot{\theta}\, \hat{\boldsymbol{\theta}} .\]Differentiating again,
\[\begin{aligned} \ddot{\mathbf{r}} & =\ddot{r} \hat{\mathbf{r}}+\dot{r} \dot{\hat{\mathbf{r}}}+\dot{r} \dot{\theta} \hat{\boldsymbol{\theta}}+r \ddot{\theta} \hat{\boldsymbol{\theta}}+r \dot{\theta} \dot{\hat{\boldsymbol{\theta}}} \\ & =\ddot{r} \hat{\mathbf{r}}+\dot{r} \dot{\theta} \hat{\boldsymbol{\theta}}+\dot{r} \dot{\theta} \hat{\boldsymbol{\theta}}+r \ddot{\theta} \hat{\boldsymbol{\theta}}-r \dot{\theta}^2 \hat{\mathbf{r}} \\ & =\left(\ddot{r}-r \dot{\theta}^2\right) \hat{\mathbf{r}}+(2 \dot{r} \dot{\theta}+r \ddot{\theta}) \hat{\boldsymbol{\theta}} . \end{aligned}\]For a central force \(\mathbf{F} = F_r(r)\,\hat{\mathbf{r}}\), Newton’s second law gives
\[m\left(\ddot{r}-r \dot{\theta}^2\right) \hat{\mathbf{r}}+m(2 \dot{r} \dot{\theta}+r \ddot{\theta}) \hat{\boldsymbol{\theta}}=F_r(r) \hat{\mathbf{r}} ,\]and comparing components,
\[\begin{aligned} \ddot{r}-r \dot{\theta}^2 & =F_r(r) / m, \\ 2 \dot{r} \dot{\theta}+r \ddot{\theta} & =0 . \end{aligned}\]The second equation can be written as
\[\frac{1}{r} \frac{d}{d t}\left(r^2 \dot{\theta}\right)=0 \quad \Longrightarrow \quad r^2 \dot{\theta} \equiv h=\text{const.}\]To interpret \(h\), compute the angular momentum:
\[\begin{aligned} \mathbf{L}&=\mathbf{r} \times \mathbf{p}=m r\, \hat{\mathbf{r}} \times \dot{\mathbf{r}} \\ &=m r\, \hat{\mathbf{r}} \times(\dot{r} \hat{\mathbf{r}}+r \dot{\theta} \hat{\boldsymbol{\theta}}) \\ &=m r^2 \dot{\theta}\, \hat{\mathbf{n}} = m h\, \hat{\mathbf{n}}, \end{aligned}\]where \(\hat{\mathbf{n}} = \hat{\mathbf{r}}\times\hat{\boldsymbol{\theta}}\) is normal to the plane of motion. Hence
\[r^2 \dot{\theta} = h=\frac{|\mathbf{L}|}{m},\]the angular momentum per unit mass, is conserved.
Exercises
- Which quantity is conserved as a consequence of rotational symmetry? (Secondary school)
- Derive the results above using Lagrangian dynamics, which is much faster. (Undergraduate, years 2–3)
Credits
This article draws on three sources: Prof. Arjun Berera’s Introductory Dynamics course, Prof. Jenni Smillie’s Lagrangian Dynamics course, and the Wikipedia article on Noether’s theorem.
Revised on 25 October 2026. The switching argument used a symbol \(\varphi\) that was never defined, and the action integrals were missing their \(dt\). The argument now uses \(\delta q\) throughout and explains each step, vectors are in bold and the wording is tighter. Previously titled “Conservations in Physics - Noether’s Theorem”.
Filed under Classical Mechanics.