Sundman’s Power Series Solution to the Three-Body Problem (Part I)
Summer research 2024: the three-body problem · Part 7 of 11
A weekly research log from my summer project at the University of Edinburgh, supervised by Prof. Jenni Smillie.
← Problem of Two Fixed Centres (Part II) · Sundman's Power Series Solution to the Three-Body Problem (Part II) →
In 1912 Karl F. Sundman found a convergent power-series solution to the three-body problem, valid whenever the total angular momentum is non-zero. In principle this is a general solution, but its convergence is so slow that it is of no practical use. This post outlines how it works.
Key points of Sundman’s paper
- At a double (binary) collision, the distance to the third, non-colliding body stays bounded.
- A triple collision can only occur if the total angular momentum (the “area integral”) is zero.
- At a double collision, the velocities and accelerations of the colliding bodies tend to infinity.
- The unit vector along the line joining the two colliding bodies tends to a limit.
- The singularity of a collision between a given pair of bodies can be removed by introducing a new independent variable \(u\).
- A different independent variable \(w\) removes all the double-collision singularities at once, allowing any number and combination of double collisions.
- The coordinates of the three bodies can then be expanded as power series in \(w\).
- These series converge for all time, although extremely slowly.
The regularising variable \(w\)
Where the singularities come from
The variable \(u\) regularises a collision between one particular pair of bodies, say \(m_0\) and \(m_1\). The equations of motion contain terms such as \(1/r_0\) and \(1/r_1\), where the \(r_i\) are mutual distances, so a collision involving a different pair still produces a singularity. We need a variable that treats all three pairs symmetrically.
Definition
Sundman’s variable \(w\) is defined by
\[dt= \Gamma\, dw, \qquad w=0 \text{ at } t=0,\]where
\[\Gamma = \left(1-e^{-r_0/l}\right)\left(1-e^{-r_1/l}\right)\left(1-e^{-r_2/l}\right)\]for a suitable constant \(l\), and \(r_0, r_1, r_2\) are the three mutual distances. The definition is symmetric in the three distances, so every double collision is regularised in the same way.
Convergence in a strip
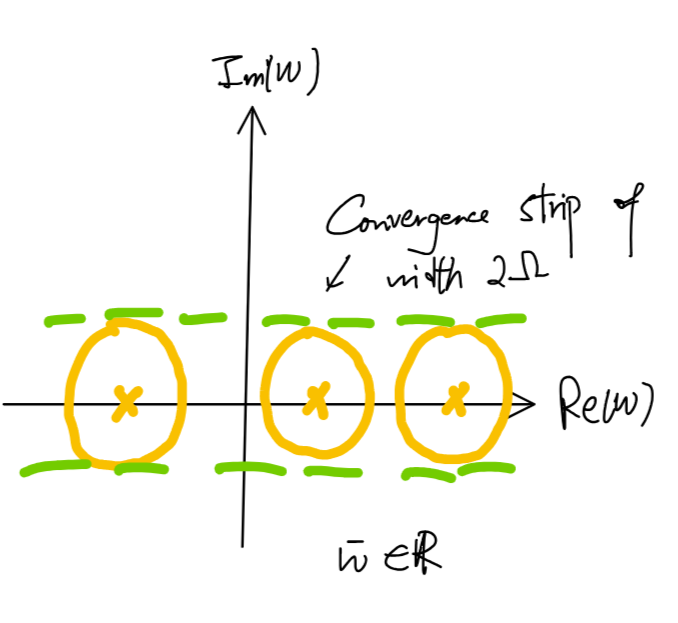
After a long analysis (Yeomans gives a complete account), one finds that the coordinates are holomorphic functions of \(w\) in a strip around the real axis,
\[\lvert \operatorname{Im} w\rvert < \Omega,\]for some \(\Omega > 0\): a strip of width \(2\Omega\).
Mapping the strip to a disc
A power series converges in a disc, not a strip, so we map the strip conformally onto the unit disc.
Write the strip as \(S = \{s : \lvert\operatorname{Im} s\rvert < \beta\}\). The exponential map
\[g(s) = e^{\pi s / (2\beta)}\]sends \(S\) onto the right half-plane \(\{\operatorname{Re} z > 0\}\). Points of the right half-plane are closer to \(1\) than to \(-1\), i.e. \(\lvert z-1\rvert < \lvert z+1\rvert\), so the Möbius transformation
\[h(z)=\frac{z-1}{z+1}\]maps the right half-plane onto the unit disc. The composition \(h \circ g\) therefore maps \(S\) onto the unit disc. With \(\beta = \Omega\), the new variable \(\tau = h(g(w))\) satisfies
\[w = \frac{2 \Omega}{\pi} \log\frac{1+ \tau}{1- \tau},\]and the coordinates become power series in \(\tau\) that converge for \(\lvert\tau\rvert < 1\). The whole real time axis, \(-\infty < w < \infty\), corresponds to the real interval \(-1 < \tau < 1\) (a good exercise to check).
This is also the source of the slow convergence: late times are squeezed towards the boundary \(\lvert\tau\rvert = 1\) of the disc of convergence, where power series converge very slowly.
When does it work?
The series exist whenever the total angular momentum is non-zero,
\[\mathbf{c} = m_0 (\mathbf{r}_0 \times \mathbf{v}_0) + m_1 (\mathbf{r}_1\times \mathbf{v}_1) + m_2 ( \mathbf{r}_2 \times \mathbf{v}_2) \neq \mathbf{0} .\]That covers essentially every case, including double collisions, but not triple collisions, which require \(\mathbf{c}=\mathbf{0}\).
The catch is the convergence rate: Belorizky estimated that something like \(10^{8\,000\,000}\) terms would be needed for useful accuracy in a simple case. Part 8 goes through the estimate.
Summary
Sundman found an independent variable \(w\) in which every double collision is regular. The solution is analytic in a strip of width \(2\Omega\) around the real \(w\)-axis, which a conformal map sends to the unit disc in a new variable \(\tau\). The resulting power series in \(\tau\) solve the three-body problem for all time whenever the angular momentum is non-zero, but they converge far too slowly to be useful.
Progress
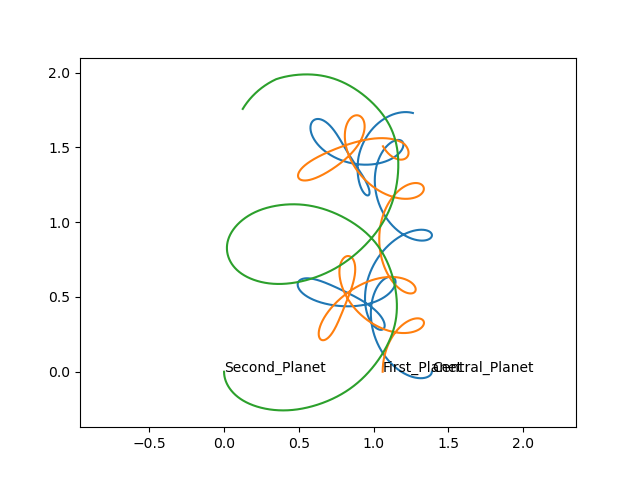
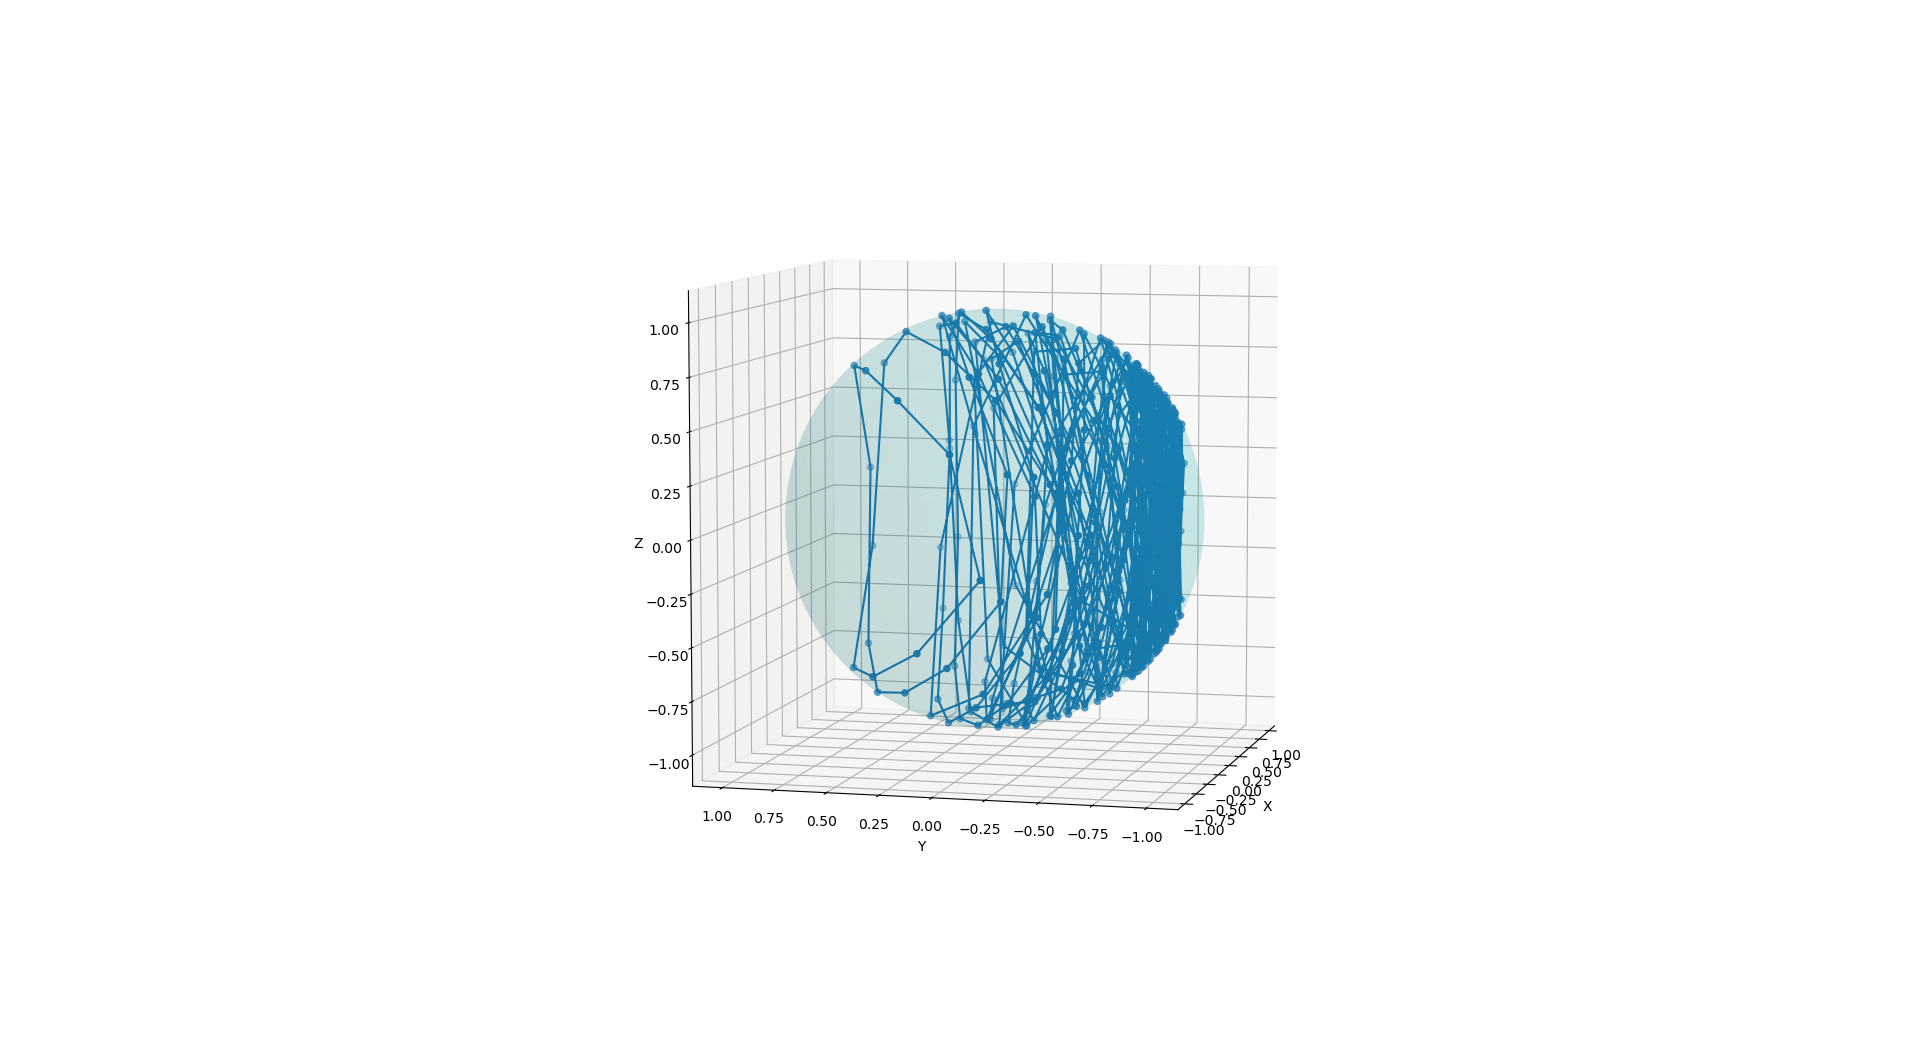
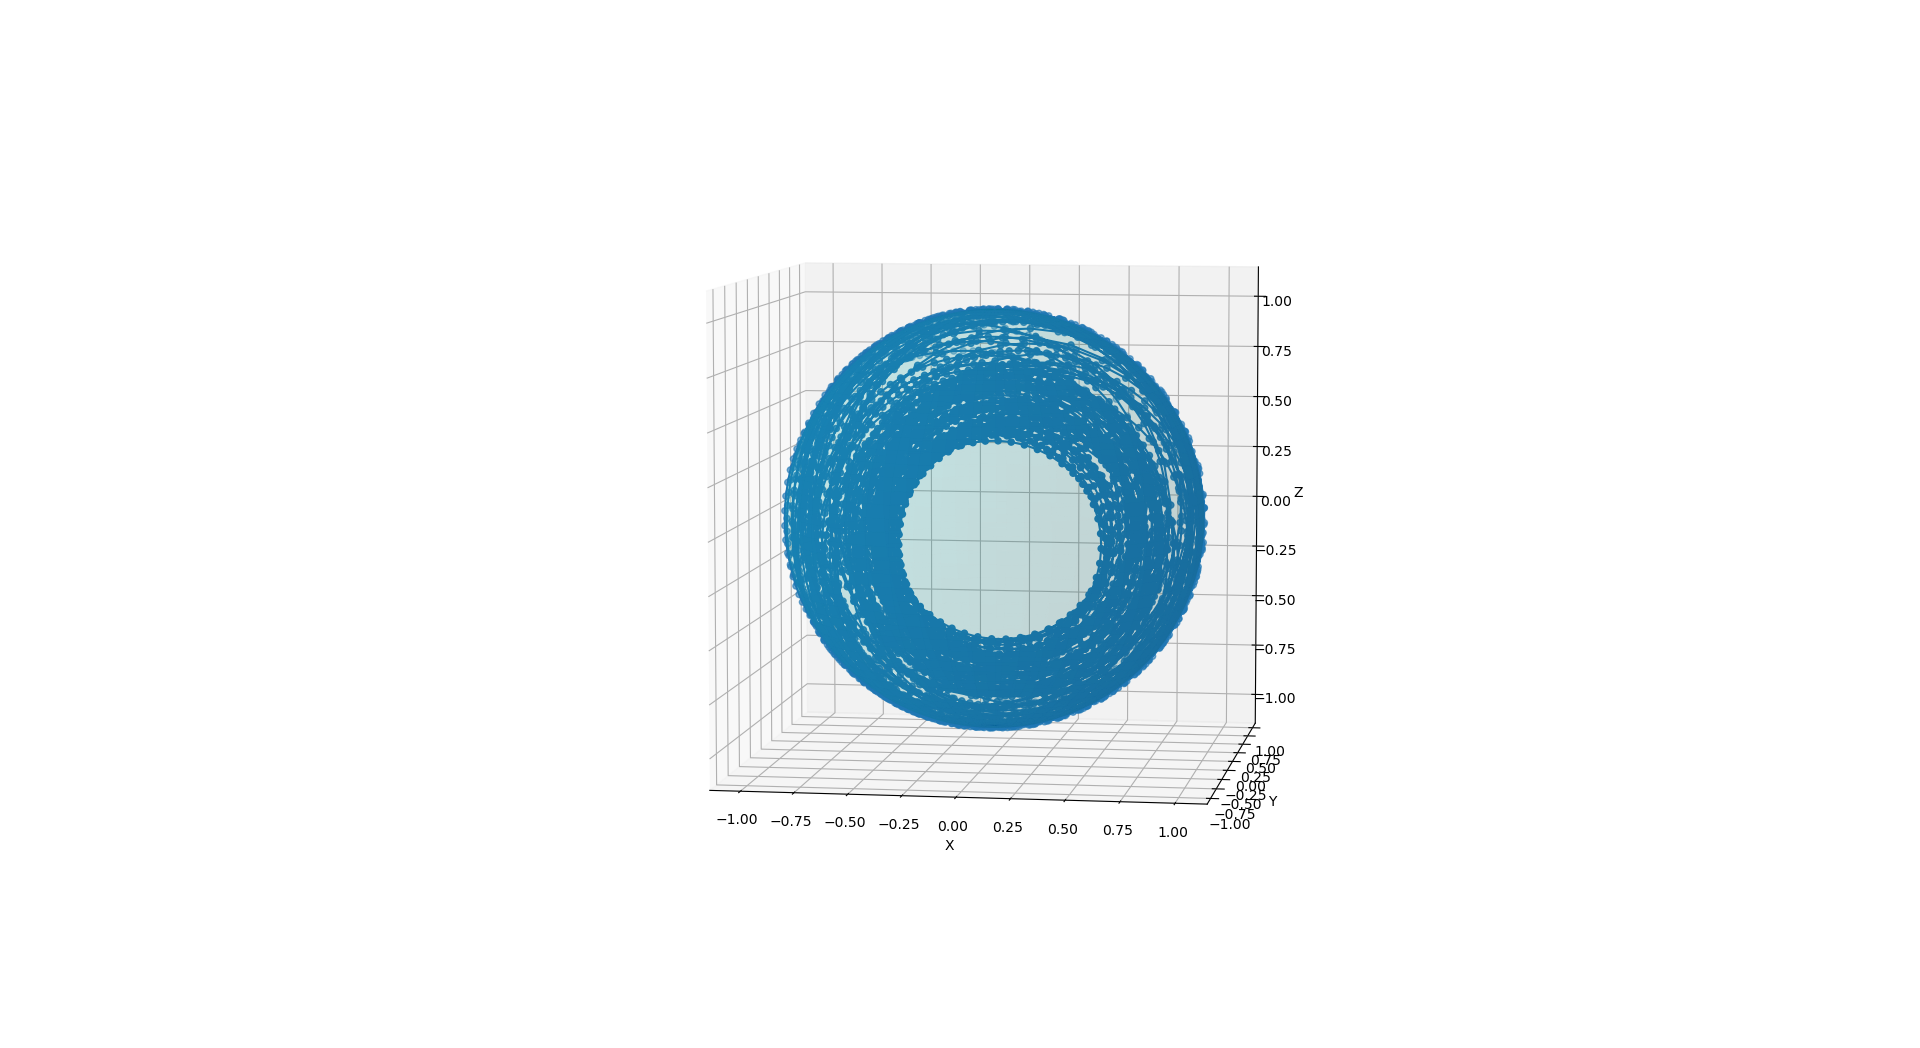
Alongside the reading, I have been simulating the Broucke–Hadjidemetriou–Hénon (BHH) orbits. Here is one, with its curve on the shape sphere seen from two angles:
Credits
This post is based on D. K. Yeomans’s exposition of Sundman’s regularisation of the three-body problem, NASA technical memorandum X-640-66-481 (1966), and on notes by Peter Senchyna.
Changes on 25 October 2026
What was wrong.
- The map from the right half-plane to the unit disc was written \(h(z) = \lvert z-1\rvert / \lvert z+1\rvert\), which is a number, not a map. It is the Möbius transformation \(h(z) = (z-1)/(z+1)\).
- The strip was written \(\operatorname{Im} s \le \beta\) instead of \(\lvert\operatorname{Im} s\rvert < \beta\), and the condition on \(w\) used \(\lvert w - \bar w\rvert\), which is twice \(\lvert\operatorname{Im} w\rvert\).
- A reference link no longer worked.
What changed. All are fixed, and the reference now points to the copy on NASA’s Technical Reports Server.